
Specialized robots extend human reach from high-risk, hard-to-access, or repetitive work positions. Milliseconds in Confined Spaces: How Remote Control Latency Affects Operator Experience—this is also an important entry point for judging whether a solution can operate stably over the long term.
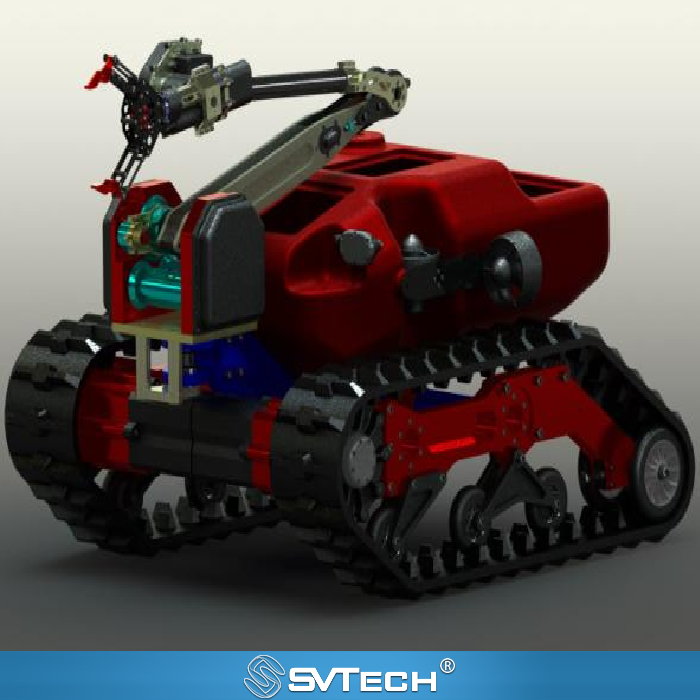
Milliseconds in Confined Spaces: How Remote Control Latency Affects Operator Experience
Latency includes acquisition, transmission, display, and control execution; what the operator sees may be a slightly earlier state. Persistent and predictable latency differs in its effect on operation from occasional stuttering.
Truly usable robot capability comes from the coordination among mechanics, perception, control, and on-site personnel. It may appear to belong to a single component, but in practice it affects the rhythm and quality of the entire service process. Validate under actual task loads and observe peaks and jitter; establish appropriate operating methods in training; stop or recover according to procedures in abnormal situations, rather than compensating by making larger control inputs.
In narrow passages, discontinuous image updates can easily lead to overcorrection. Testing should record the overall control and video experience, not just average network latency.
Technical Principles and Engineering Boundaries
Specialized robots bring the mobile chassis, actuators, sensors, communications, and human-machine interface into one on-site system. "Milliseconds in Confined Spaces: How Remote Control Latency Affects Operator Experience" reminds us that product specifications need to be understood in the context of ground conditions, payload state, operator location, and task duration. Speed, gradeability, endurance, or ingress protection are not absolute conclusions divorced from the environment; only under specified routes, obstacles, temperatures, and control methods do a robot's capability boundaries have engineering significance.
Application Scenarios and Implementation Path
Firefighting, hazardous environment inspection, industrial inspection, and emergency rescue are the most valuable application directions for specialized robots. Their common goal is to extend personnel perception and operational range and, under suitable conditions, reduce direct exposure risk. Before deployment, the task area, communication conditions, entry and recovery paths, personnel responsibilities, and information handover should be designed together, so that robot intelligence truly serves on-site decision-making rather than merely demonstrating individual actions.
Project Validation and Continuous Optimization
To ground this technical discussion on "Milliseconds in Confined Spaces: How Remote Control Latency Affects Operator Experience" in real projects, the validation phase should record configuration versions, environmental conditions, measurement locations, and task results together. Validate under actual task loads and observe peaks and jitter; establish appropriate operating methods in training; stop or recover according to procedures in abnormal situations, rather than compensating by making larger control inputs. Such information is not supplementary documentation but the shared basis for interpreting results, reproducing performance, and continuously optimizing.
Related Support from SV Tech
Zhuhai SV Tech Co. Ltd. provides product documentation, project requirement communication, and configuration boundary verification for specialized robots and related industry applications. For topics such as "Milliseconds in Confined Spaces: How Remote Control Latency Affects Operator Experience," you can describe the task conditions, target outcomes, on-site environment, and existing equipment together, and Mr. Liu (+86 18688194199, lhc1983@gmail.com) will assist with coordination; specific models, performance, and delivery scope are subject to confirmed documentation and project validation.
Average latency can mask brief but severe stalls; continuous recording is more helpful than occasionally checking network values. Trained personnel can complete similar actions on the same route, and analysis can combine misoperations and stalls. Communication performance must also match the permitted operating speed, as specified by the operating plan.
Only by continuously accumulating this experience can teams make similar tasks increasingly reliable.
